🚀 QNX SDP 8.0 vs. 7.1: A Generational Shift for Software-Defined Vehicles #
The transition from QNX SDP 7.1 to QNX SDP 8.0 is not an incremental update—it represents a ground-up architectural redesign to support the high-performance computing (HPC) demands of modern, software-defined vehicles (SDVs). As automotive platforms consolidate dozens of ECUs into centralized compute domains, operating system scalability, determinism, and security become mission-critical.
Performance and scalability at the core #
-
Up to 20× scheduling throughput
QNX SDP 8.0 introduces a next-generation microkernel capable of delivering up to 20 times higher scheduling throughput compared to 7.1, addressing the explosion of concurrent workloads from ADAS, infotainment, and vehicle networking. -
Designed for large multi-core SoCs
While QNX 7.1 scaled effectively on 4–8 cores, QNX 8.0 is engineered for SoCs with up to 64 cores, offering near-linear scalability without the contention and bottlenecks common in traditional OS architectures. -
Redesigned thread executive
A new scheduling engine enables fine-grained thread management and configurable core clustering, allowing safety-critical real-time workloads to run on performance cores while background services execute on efficiency cores.
Hardware and language modernization #
-
Next-generation CPU architectures
Native support for Armv9 and x86-64, including hardware security features such as Pointer Authentication (PAC) and Branch Target Identification (BTI). -
Modern development toolchain
Built on a GCC 12–based toolchain, QNX SDP 8.0 officially supports C++17/20, Rust, and Python, enabling memory-safe language adoption for safety- and security-critical components. -
Automotive-grade networking
Theio-socknetworking stack—introduced in QNX 7.1—has been further optimized for high-bandwidth automotive Ethernet and now supports IEEE TC8 conformance, enabling deterministic communication at scale.
Real-time and security enhancements #
-
Lower latency and reduced jitter
More granular and preemptible context switching significantly reduces jitter, which is essential for ADAS and autonomous driving workloads where microseconds matter. -
Improved security observability
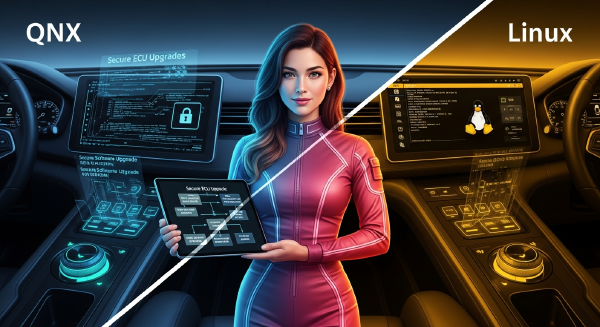
Enhanced security event libraries such aslibsecpolevprovide real-time visibility into privilege usage, directly supporting ISO 21434 cybersecurity compliance and in-field monitoring.
⚡ How Virtual ECUs (vECUs) Accelerate Time-to-Market #
As vehicles become software-defined, software velocity—not hardware availability—becomes the primary bottleneck. Virtual ECUs (vECUs) remove this constraint by decoupling software development and validation from physical ECUs.
Shift-left development #
-
Hardware-independent development start
Engineers can run QNX and ECU software on cloud platforms such as AWS or Azure months before production silicon is available. -
Massive test parallelization
Thousands of automated tests can run simultaneously in the cloud, eliminating dependence on limited physical test benches.
Deterministic debugging #
-
Complete system visibility
Virtual environments provide full access to CPU state, memory, and registers, eliminating elusive “heisenbugs” common on physical hardware. -
Perfect reproducibility
Teams can freeze a system at the exact point of failure and share that identical state globally for faster root-cause analysis.
CI/CD and OTA readiness #
-
Continuous validation pipelines
Every code commit can be automatically deployed to a virtual vehicle, tested across safety-critical domains such as braking, steering, and powertrain. -
Reduced OTA risk
Software updates can be validated against all virtual configurations of a vehicle model before deployment, dramatically lowering the risk of field failures or bricked ECUs.
📊 QNX SDP 7.1 vs. QNX SDP 8.0: Key Differences #
| Dimension | QNX SDP 7.1 | QNX SDP 8.0 |
|---|---|---|
| Target scale | 4–8 cores | Up to 64 cores |
| Kernel architecture | Classic microkernel | Next-generation HPC-oriented microkernel |
| Scheduling throughput | Baseline | Up to 20× higher |
| Thread management | Traditional scheduler | Thread Executive with core clustering |
| CPU support | Armv8, x86 | Armv9, x86-64 with PAC/BTI |
| Toolchain | Legacy GCC | GCC 12, C++17/20, Rust, Python |
| Networking | io-sock (initial) | Optimized io-sock with TC8 support |
| Security observability | Limited | Real-time security event monitoring |
| SDV and vECU support | Partial | First-class support |
🧠 Bottom Line #
QNX SDP 8.0, combined with vECU-driven development, provides a foundational platform for HPC-class, software-defined vehicles. Together, they enable faster development cycles, stronger security postures, and predictable real-time behavior—without compromising functional safety or scalability.